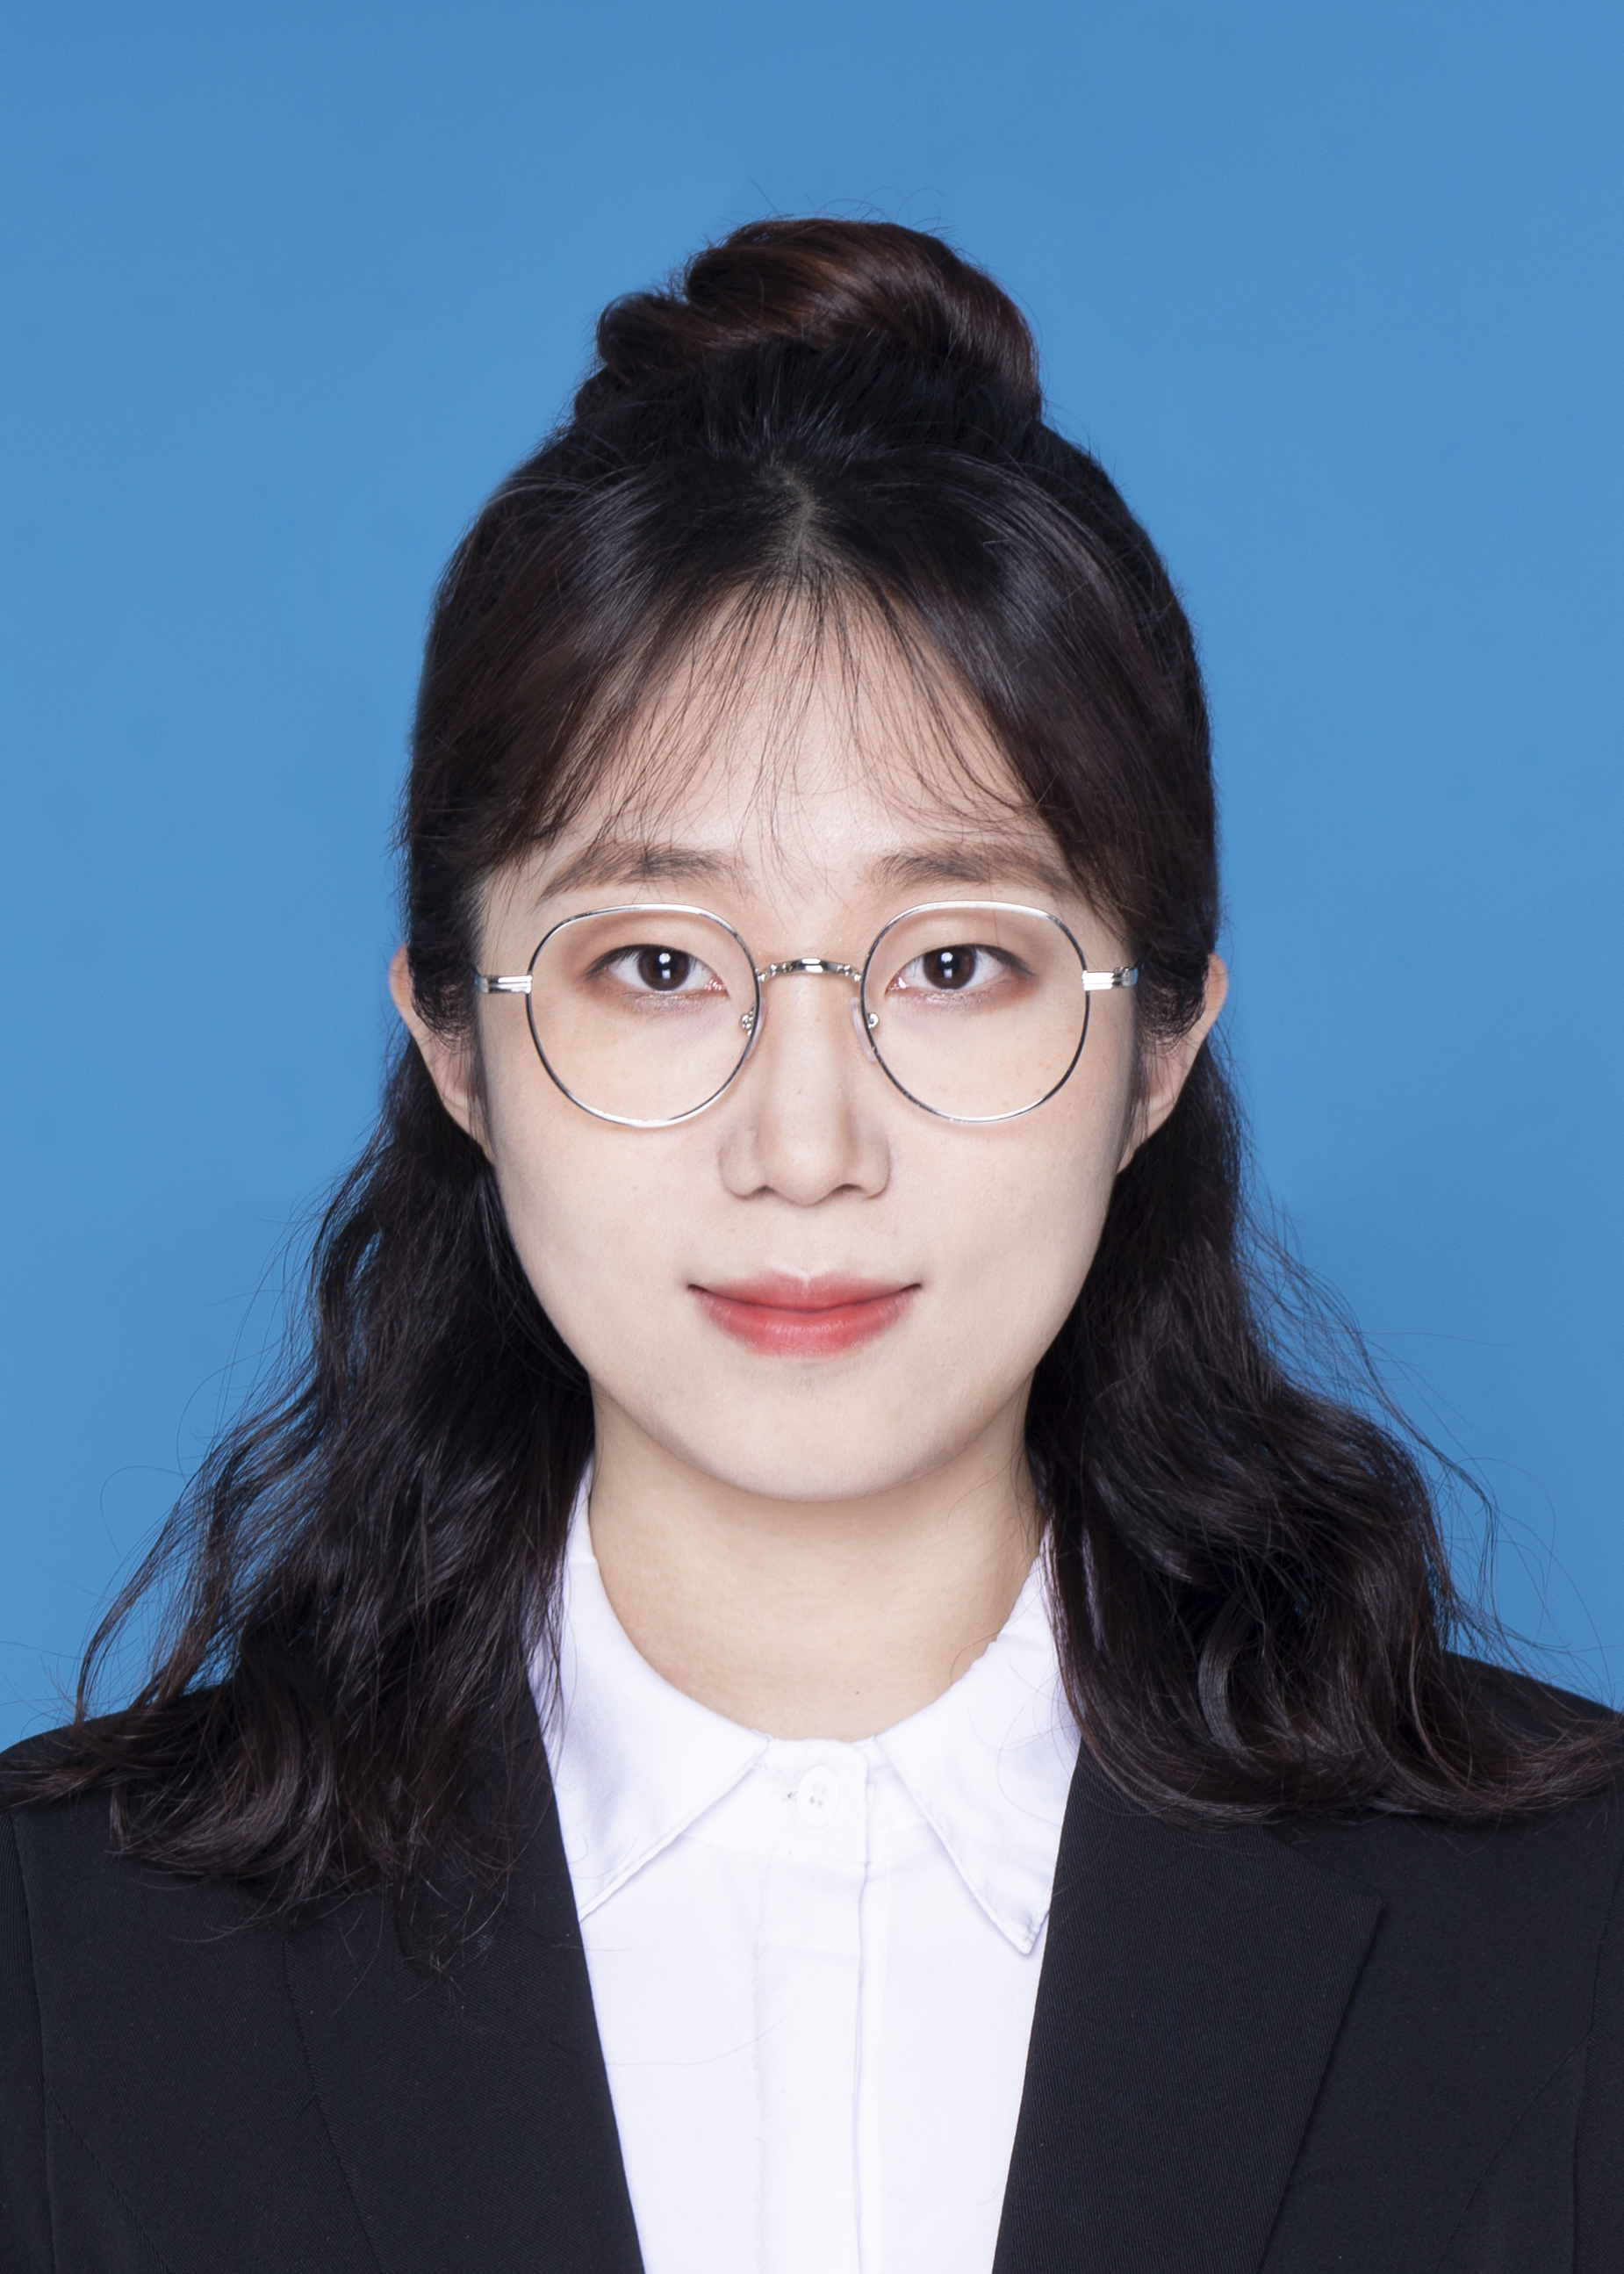
王秀博,女,工学博士,讲师,研究生导师。
联系方式
电子邮件:wangxiubo@neuq.edu.cn
办公地点:科技楼5009
研究方向
1.全驱系统方法预测控制与应用;
2.空间机器人导航制导控制;
3.人机交互博弈控制
教育背景
2019.09-2024.09 哈尔滨工业大学 控制科学与工程 博士
工作履历
2024.10-至今 东北大学秦皇岛分校
学术兼职
中国自动化学会全驱系统理论与应用专业委员会委员
IFAC World Congress 2026, Co-Session Chair
IFAC ACA 2026,Co-Session Chair, AE
Conference on Fully Actuated System Theory and Applications (FASTA), Session Chair, AE
Chinese Control Conference (CCC), Session Chair
IEEE Trans on SMCS, Cyber, TII, AES, ASE等期刊审稿人
科研情况
【在研项目】
1.国家自然科学基金青年基金(C类),主持
2.全驱系统理论与应用青年研究基金,主持
3.河北省自然科学基金青年基金,主持
4.河北省高等学校青年基金项目,主持
5.xxx-控制板定制开发,主持
6.人民政府办公室调研课题,主持
7.中央高校基本科研业务费青年启动项目,主持
8.东北大学秦皇岛分校引进人才启动基金,主持
9.国家基础科学中心项目,参与
10.国家科技重大专项,参与
【结题项目】
1. 全驱系统理论与应用青年研究基金(学生),主持
2. 国家自然科学基金重大项目,参与
学术成果
【论文、专著与专利等】
发表SCI/EI检索学术论文20余项
【代表性学术论文】
1. Wang Xiubo, Duan Guangren. Predictive control for Euler–Lagrange systems with input saturation and dead-Zone: A FAS approach [J]. IEEE Transactions on Systems, Man, and Cybernetics: Systems, 2025, 55 (9): 5935-5945.
2. Wang Xiubo, Duan Guangren. Fully actuated system approaches: Predictive elimination control for discrete-time nonlinear time-varying systems with full state constraints and time-varying delays[J]. IEEE Transactions on Circuits and Systems I: Regular Papers, 2024, 71(1): 383-396.
3. Wang Xiubo, He Xinyi, Xu Lixue, Duan Guangren. Fully Actuated Iterative Learning Predictive Control for Spacecraft Batch Fly-Around with Batch-Varying Reference Trajectories [J]. Science China Technological Sciences, 2026, DOI: 10.1007/s11431-026-3399-8.
4. Xu Lixue, Wang Xiubo*, Duan Guangren. Bi-level predictive safety control for multi-axis CNC systems based on FAS approaches [J]. Control Engineering Practice, 2026, 169: 106798.
5. Xu Lixue, Wang Xiubo*, Duan Guangren. Hierarchical Predictive Sliding Mode Control for Under-actuated UAV: A FAS Approach [J]. IEEE Transactions on Aerospace and Electronic Systems, 2026, 62:15239-15249.
6. Wang Xiubo, Duan Guangren. Comprehensive reconstructions and predictive control for quadrotor UAV information gathering tracking missions based on fully actuated system approaches[J]. ISA Transactions, 2024, 147: 540-553.
7. Wang Xiubo, Duan Guangren. High-order fully actuated system approaches: Model predictive control with applications to under-actuated systems[J]. Journal of the Franklin Institute, 2023, 360(10): 6953-6975.
8. Wang Xiubo, He Xinyi, et al. FAS Approaches: Iterative Learning Predictive Control for Spacecraft Fly-Around Batch Processes, IFAC WC 2026.
9. 王秀博,段广仁. 带有输入饱和的非线性全驱系统级联预测控制[J]. 控制理论与应用, 2025,42(12):2419-2428.
10. 王秀博*,段广仁, 等. 低空欠驱垂直起降飞行器攻击–躲避全驱博弈控制[J]. 控制理论与应用. 2026, DOI: 10.7641/CTA.2026.60041.
讲授课程情况
研究生课程:《非线性系统控制理论》(双语)
本科生课程:《信号与系统》
指导研究生情况
每年招收2-3名硕士研究生,研究方向涵盖控制理论、航空航天与机器人等领域。支持研究生参加国内外学术会议,推荐优秀研究生到国内外知名高校或科研机构读博。